Electrical Function
Confirm whether the circuit carries main power, multicore control, servo motor power, encoder feedback, VFD output, data or a hybrid combination.
Select flexible power, control, servo, feedback and data cables according to what the circuit must carry and how the cable moves. TEBAOFLEX supports cable selection for CNC machines, automated production lines, robotic cells, gantry systems and other moving industrial equipment.
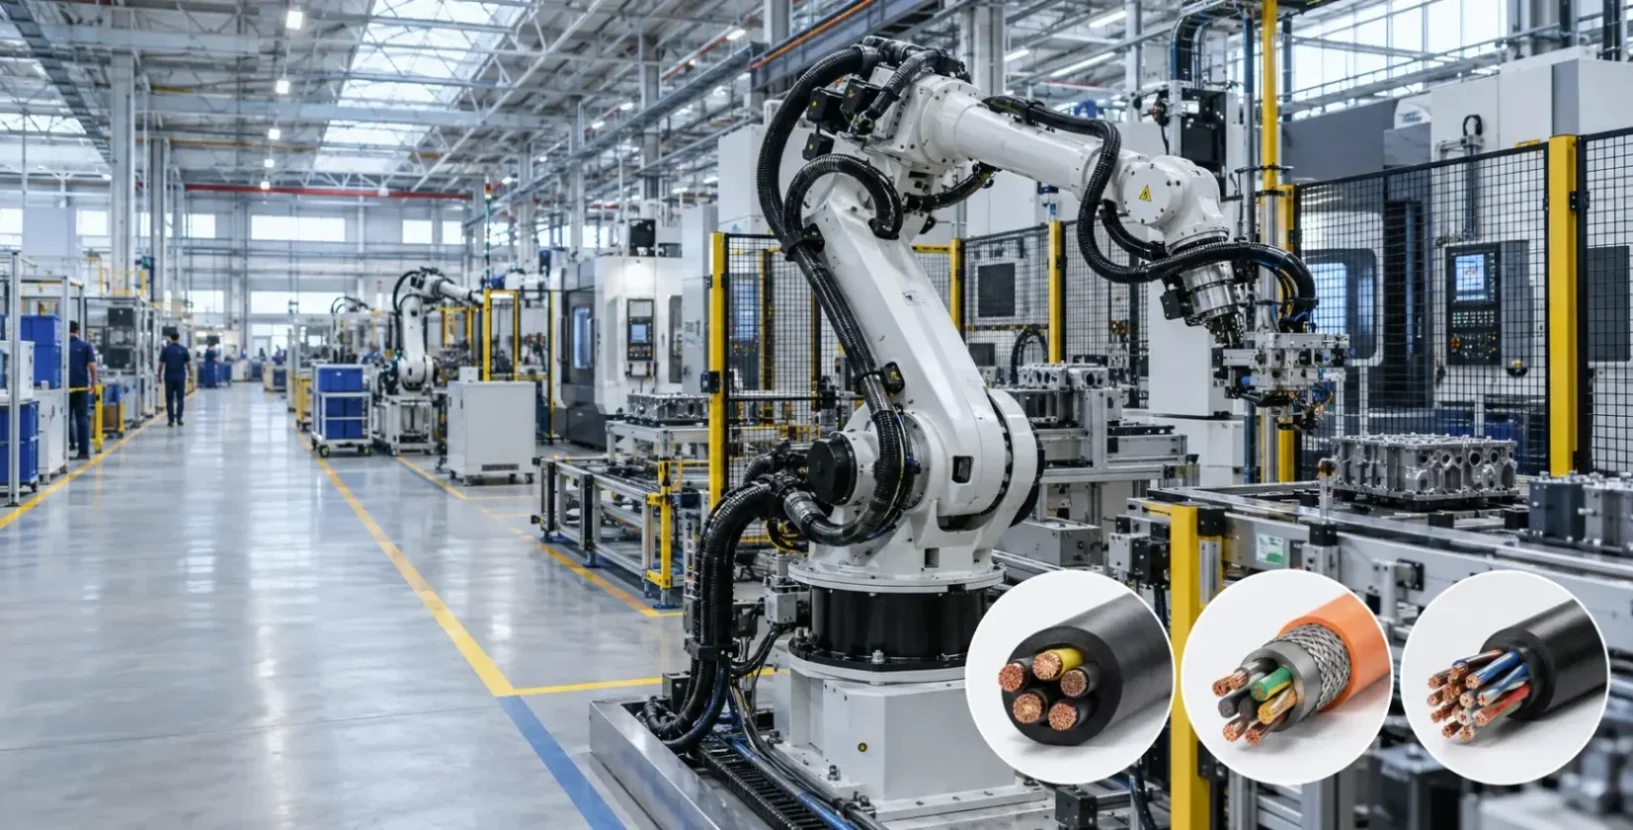
An industrial automation cable is not defined by flexibility alone. Circuit function, movement, electrical requirements and the surrounding environment must be reviewed together before choosing the conductor, insulation, shielding and sheath construction.
Confirm whether the circuit carries main power, multicore control, servo motor power, encoder feedback, VFD output, data or a hybrid combination.
Separate fixed wiring, occasional flexing, continuous cable-carrier bending and multi-axis torsion. Each motion profile places different stress on conductors and screens.
Review oil, coolant, abrasion, temperature, indoor or outdoor exposure and installation space. The sheath material must fit the confirmed operating conditions.
State voltage, conductor size, core count, shielding, signal pairs, EMC needs and any required project standard or market approval.
The same production site may require several cable duties. A control cabinet feeder can remain fixed while an axis cable bends continuously in a carrier and a robot harness twists through several planes.
Moving axes, spindles, tool changers and compact cable carriers need routing-specific control, servo, feedback and flexible power solutions.
Machine modules, sensors, actuators and moving stations require clear separation between power, control, signal and communication circuits.
Robot bases, arms, dress packs and end-of-arm tooling can introduce repeated bending, torsion and acceleration that standard flexible cable may not address.
Long carrier travel requires attention to cable weight, bend radius, speed, acceleration, abrasion and the way multiple services share the chain.
Power, charging, control and communication cables may face repeated connection, vibration, tight routing and moving equipment interfaces.
Conveyors, palletisers, pick-and-place units and packaging machinery depend on coordinated motor, sensor and control connections.
Cable movement should be described before a product family is selected. Repeated linear bending in a drag chain is different from random flexing, fixed machine wiring or torsion around a robotic axis.
Cabinet wiring, machine interconnection and service routes that move during installation or maintenance. General flexible control families such as JZ and YY/YSLY belong in this duty only when the selected product specification permits it.
Controlled repeated bending along a defined radius. Selection needs travel distance, dynamic bend radius, speed, acceleration, cycle expectations and carrier arrangement.
Multi-axis routes can combine bending and twisting. Torsion per metre, rotation range, cycle pattern and dress-pack constraints must be stated separately from drag-chain movement.
Moving machinery and mobile modules may need larger conductor sizes and mechanically robust sheaths while remaining flexible enough for the intended route.
A machine may combine several circuit types in one moving route. Keeping their functions clear helps determine core arrangement, conductor size, shielding, pair construction and whether a hybrid cable is appropriate.
Main feeds and moving power circuits are selected around voltage, load current, conductor size, installation route and mechanical duty.
Multicore control cables connect PLCs, actuators, limit switches, solenoids, interlocks and moving machine modules.
Servo power cables may incorporate motor conductors, protective earth, brake cores and shielding according to the drive and motion system.
Low-level encoder and resolver signals require suitable pair configuration, screening and flex construction to preserve signal integrity along the moving route.
Drive-to-motor connections may require screened, low-capacitance or project-specific constructions based on the converter system and installation.
Twisted pairs, overall screens or individual screens may be used where machine communication and sensitive signals travel close to power circuits.
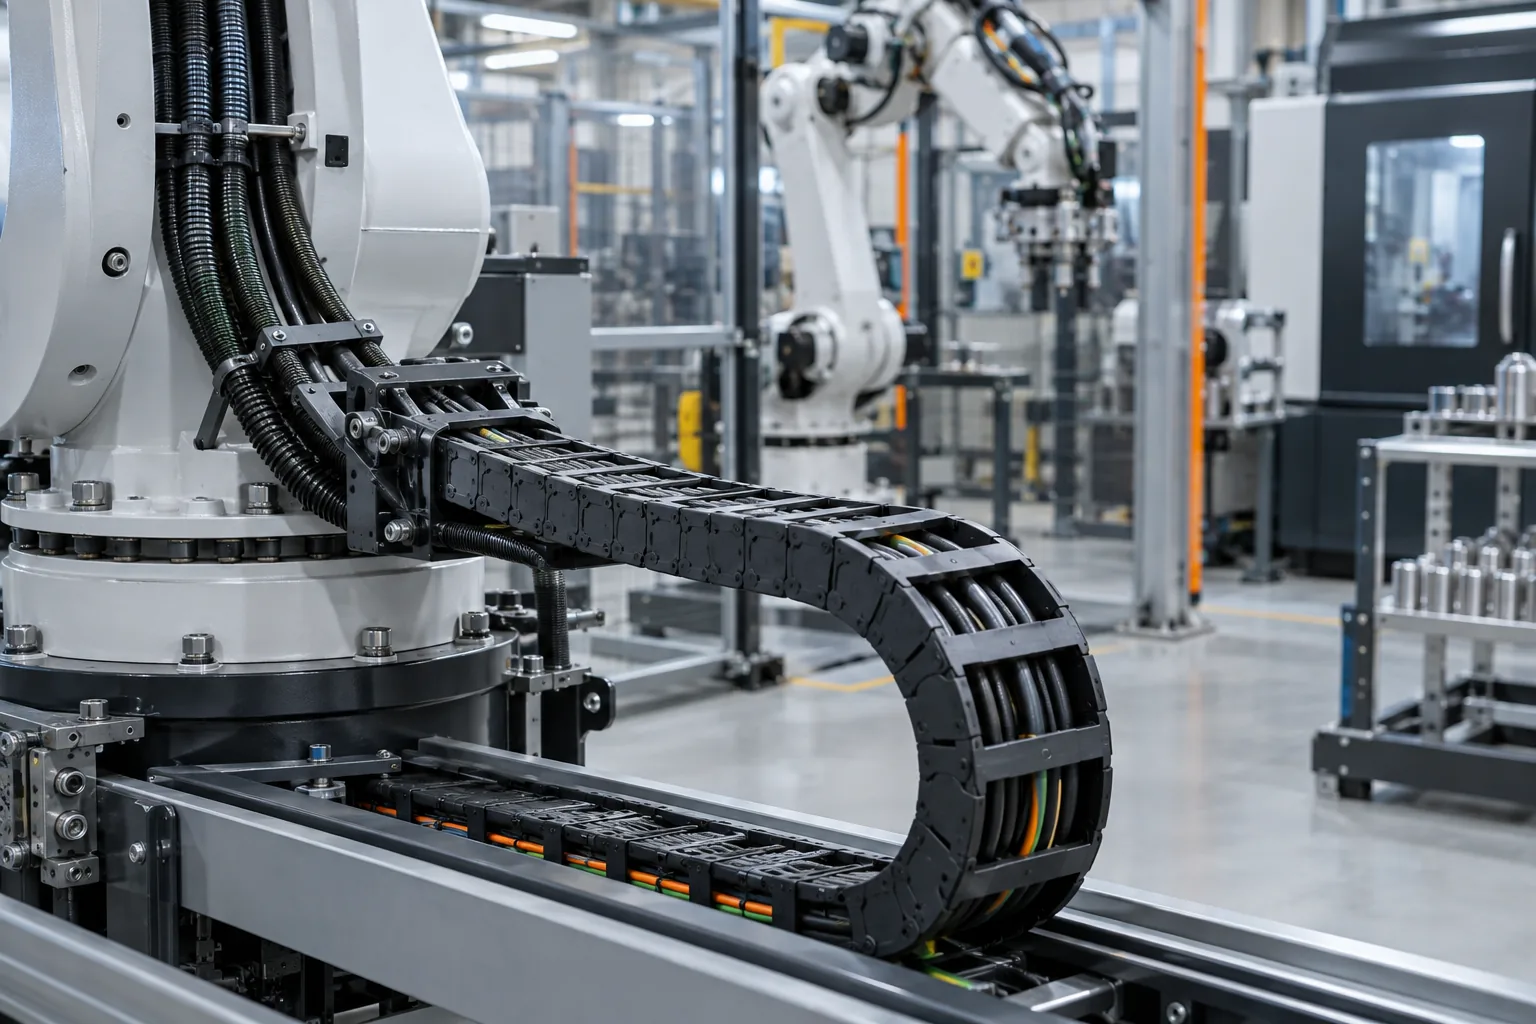
Energy chains organise power, control, servo and feedback cables along a predictable path, but the repeated bending remains demanding. The selected cable must fit the carrier geometry and the actual motion data, rather than being chosen only because it has a PUR sheath.
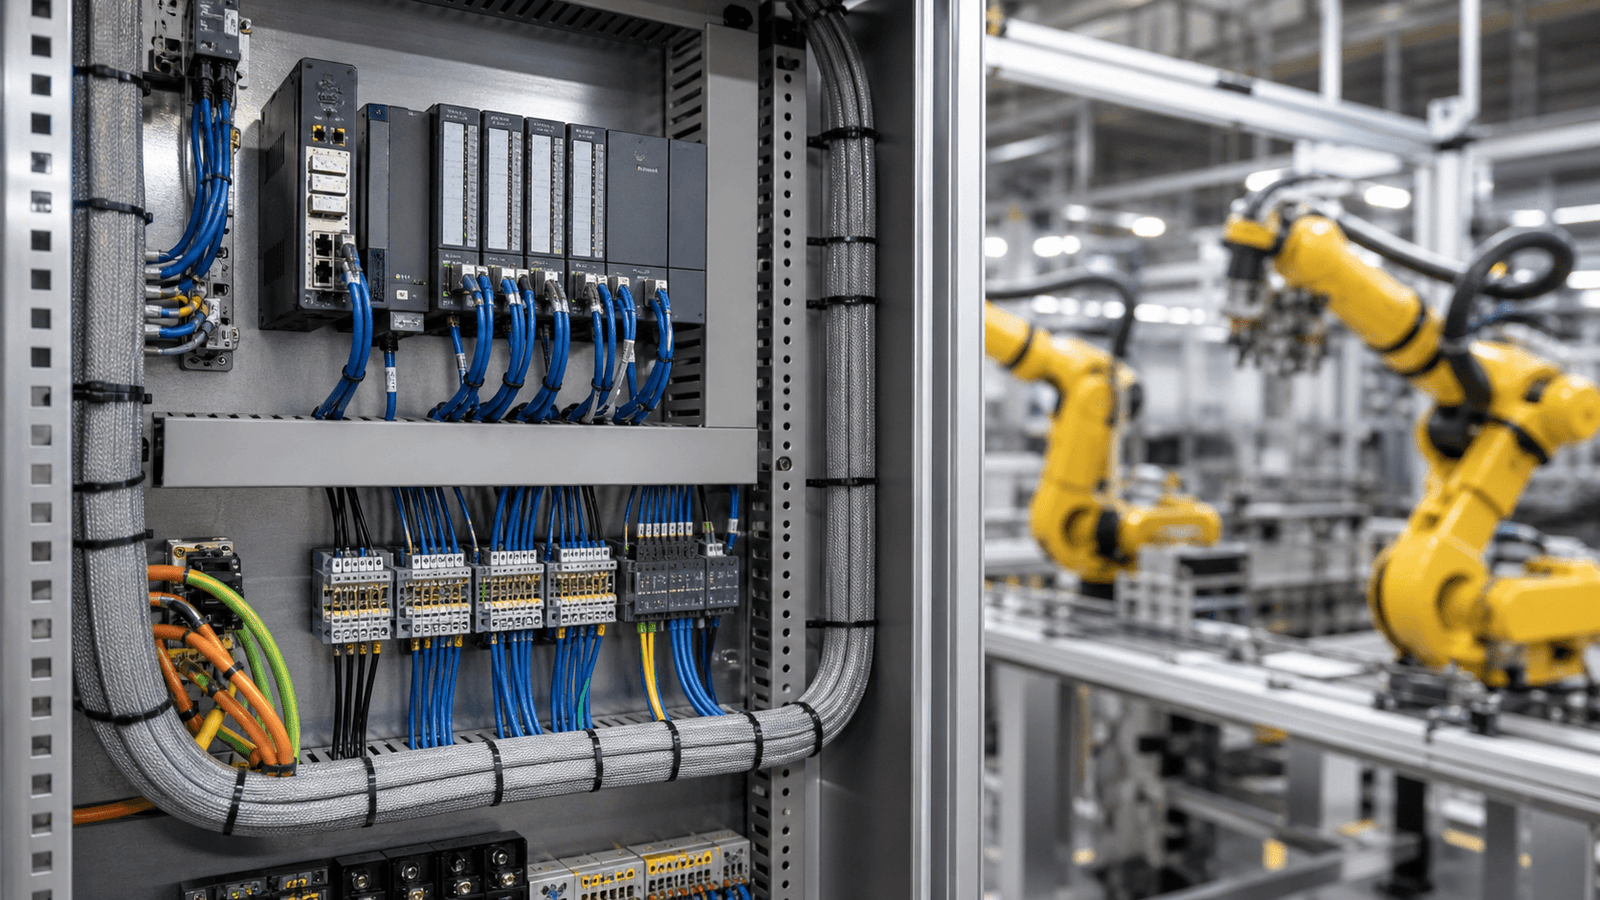
Industrial control cables link PLC outputs, sensors, actuators, limit switches, interlocks and machine modules. A cable used inside a stationary control cabinet has a different mechanical duty from one carried continuously between a fixed panel and a moving axis.
Screening should be specified when the circuit is sensitive to electromagnetic interference or routed near motors, drives and power conductors. Core identification, pair arrangement, conductor size and protective conductor requirements should be checked against the control circuit and terminal design.
Motor power and feedback signals perform different jobs. Treating them as one generic “servo cable” can obscure conductor size, brake cores, pair configuration, shielding and motion requirements.
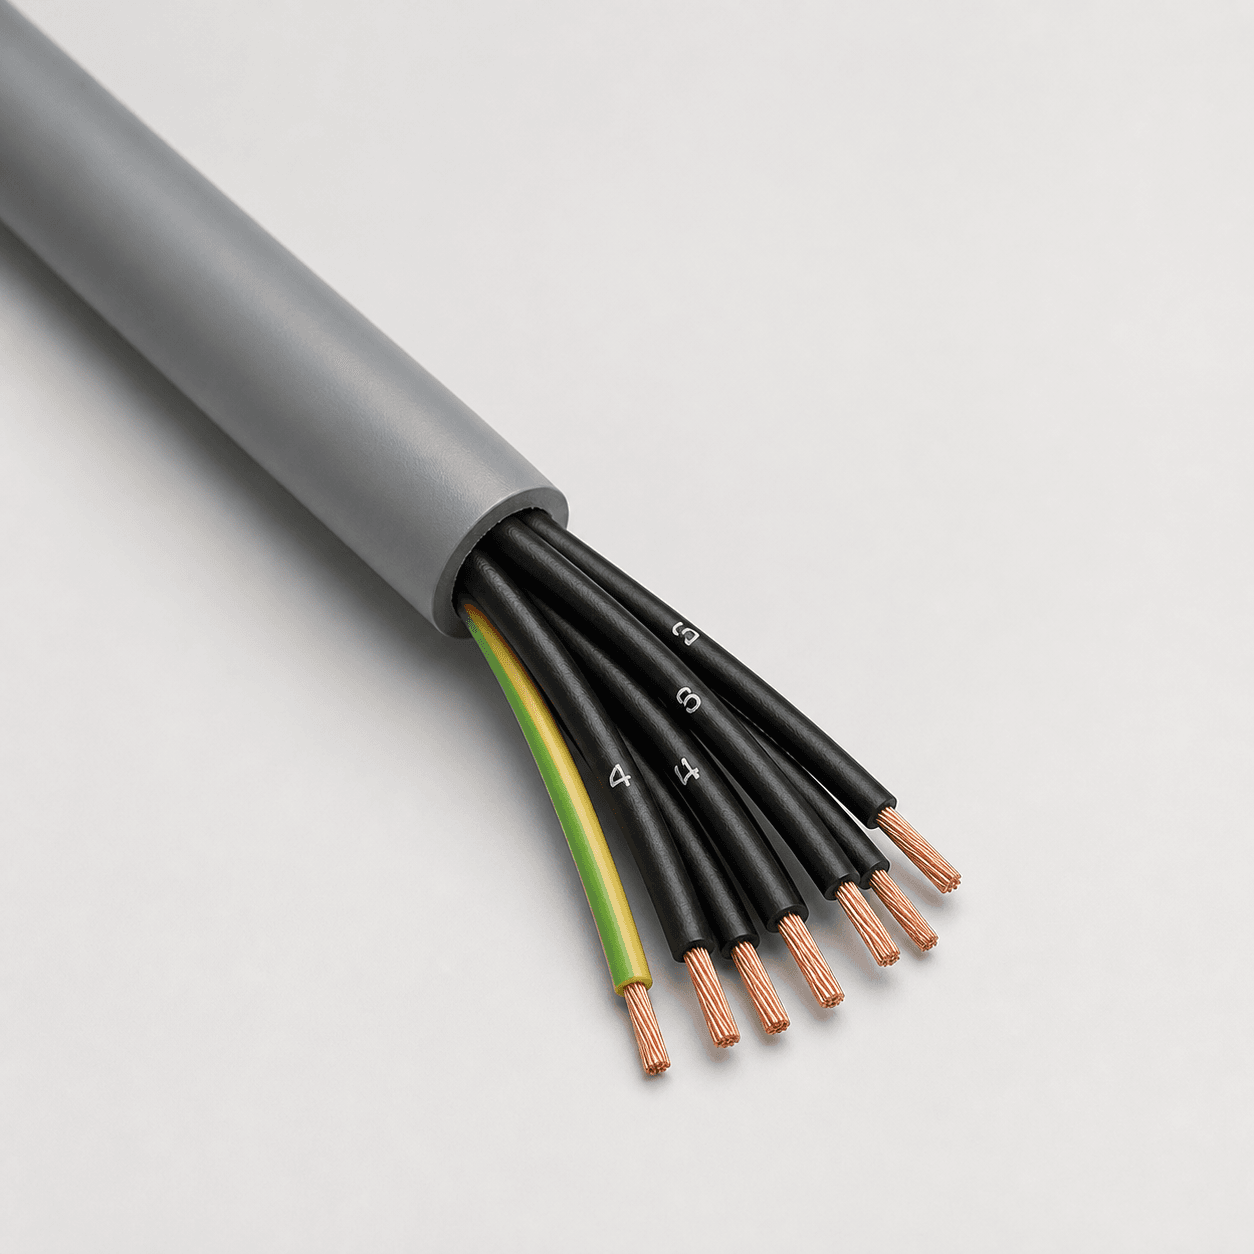
Confirm motor voltage and current, conductor size, protective earth, optional brake conductors, screen construction and the movement profile.
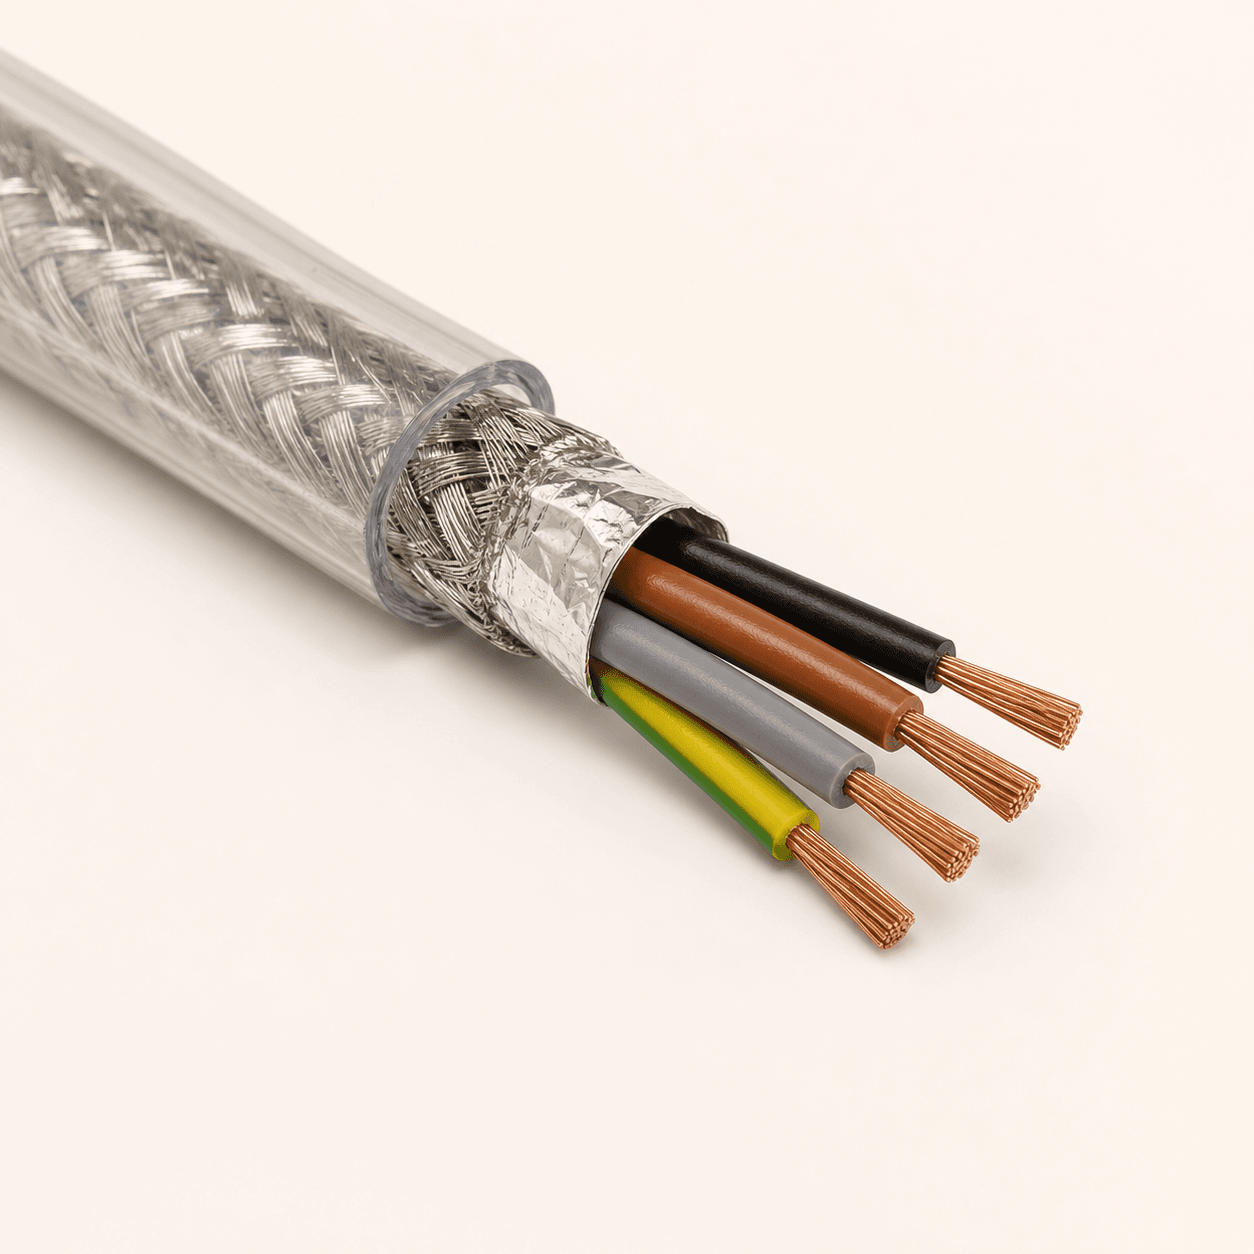
A screened VFD cable can support electromagnetic compatibility when its construction, termination and installation fit the drive system.
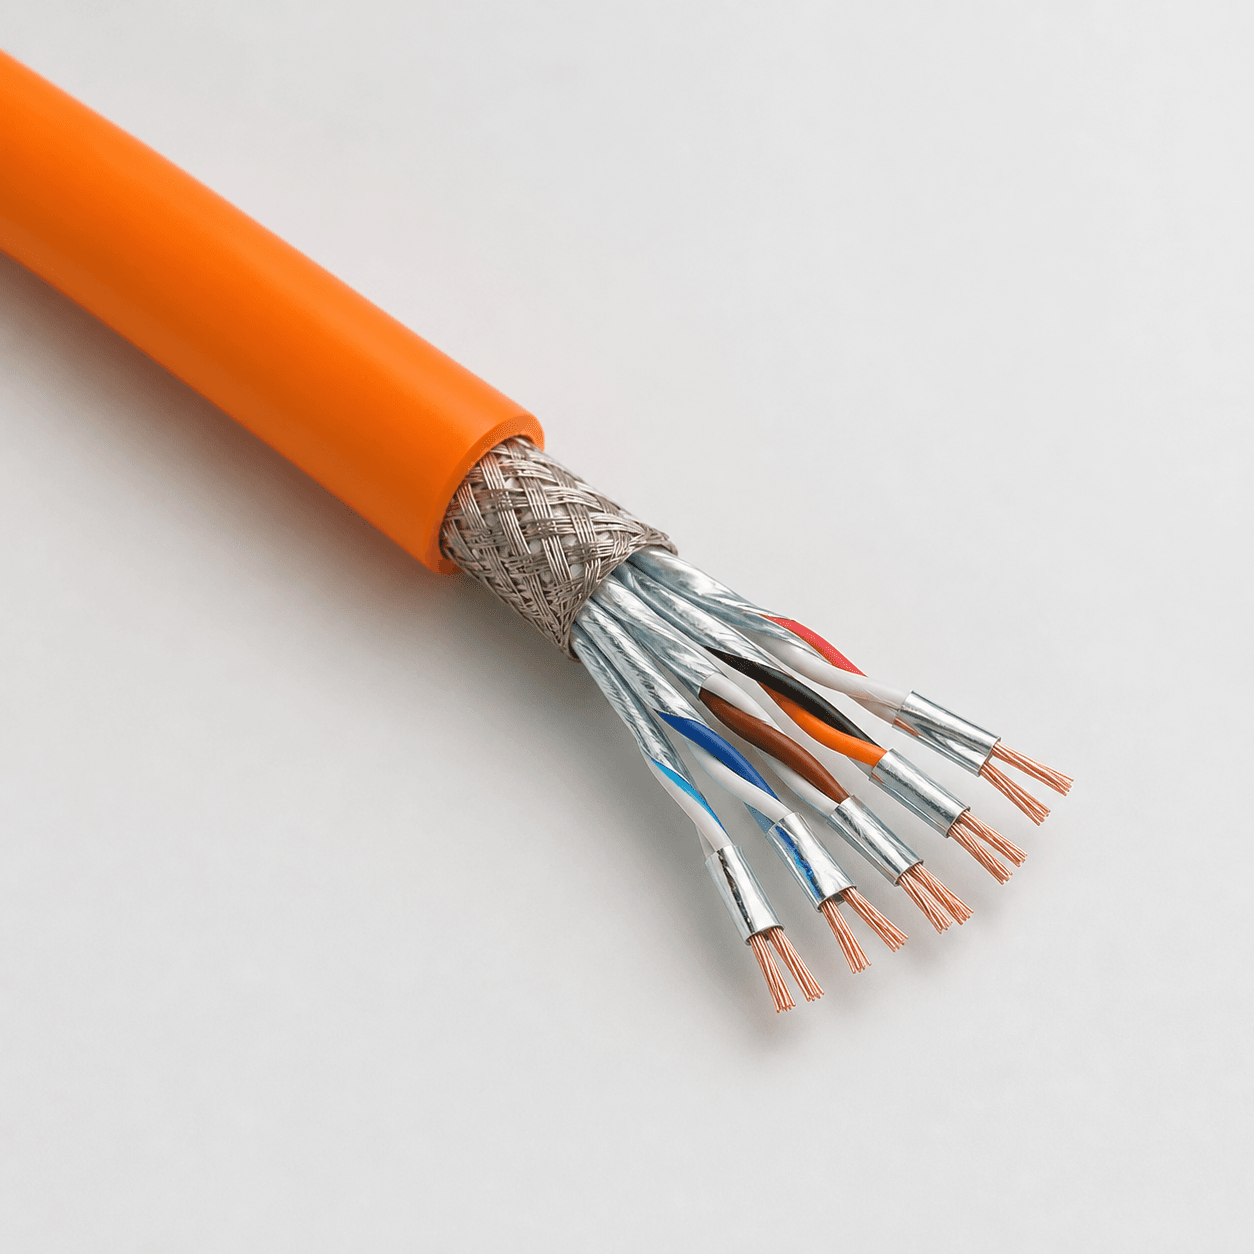
Pair layout, shielding, low-level signal integrity and repeated flexing are central when an encoder or resolver cable runs in a servo drag chain.
Automated machinery, gantry systems and mobile industrial modules can require larger flexible conductors for power distribution. The cable must be sized electrically and then checked against the route, bend radius, movement frequency and surrounding mechanical conditions.
The 0.6/1 kV BUFLEX-M PUR cable is one available product family for selected industrial machinery and moving applications. It should be evaluated as one option within a project specification, not assumed to fit every drag chain or robotic route.
A drag-chain cable is designed around controlled bending, while a robot dress pack can rotate, twist and bend across several axes. Torsion angle, torsion per metre, rotation direction, cycle pattern and the physical route should therefore be provided when a robotic cable is requested.
The harness should also be considered as a system. Connector mass, clamps, unsupported lengths and interaction with hoses can change the mechanical load on the cable. A product chosen for linear carrier movement should not automatically be presented as suitable for every robot axis.
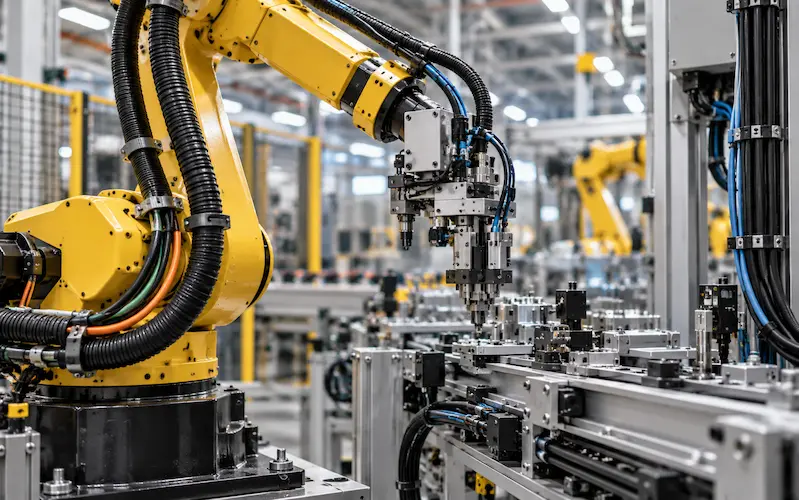
Use this matrix to identify a starting cable family. Final selection depends on the complete electrical, mechanical and environmental specification.
| Equipment / Circuit | Movement | Main Requirement | Starting Cable Solution |
|---|---|---|---|
| CNC axis | Drag chain | Repeated bending, compact routing | PUR drag-chain cable |
| Gantry system | Long-travel chain | Flex duty, abrasion, cable weight | High-flex power or control cable |
| Robot axis | Bending and torsion | Multi-axis movement | Purpose-selected robotic cable |
| Servo motor | Fixed or moving | Motor power, brake, EMC | Servo motor cable |
| Encoder / resolver | Fixed or chain | Signal integrity and screening | Feedback cable |
| PLC to moving module | Drag chain | Multicore control | Flexible control cable |
| VFD to motor | Fixed or moving | EMC and drive compatibility | Screened VFD cable |
| Machine main power | Flexible route | Current and mechanical duty | Flexible power cable |
| Control cabinet | Fixed / occasional flex | Multicore machine wiring | JZ / YY / YSLY family |
| Material handling | Moving / chain | Abrasion and repeated movement | PUR flexible cable |
These terms describe different mechanical duties. The correct choice depends on the actual route rather than the general appearance of the cable.
| Cable Duty | Typical Motion | Typical Use | Selection Note |
|---|---|---|---|
| Flexible cable | Installation or occasional movement | Cabinet and machinery interconnection | Do not assume continuous-flex capability. |
| High-flex cable | Repeated dynamic bending | Moving machine sections | Check the specified motion and bend radius. |
| Drag-chain cable | Controlled repeated bending | Cable carrier / energy chain | Provide travel, speed, acceleration and carrier data. |
| Robot cable | Multi-axis bending and torsion | Robot arm and dress pack | Define torsion and rotation pattern. |
| Reeling cable | Winding and unwinding | Cable drum | Review the separate port and crane cable application guide. |
These representative products cover different functions and motion duties. Review the individual product data and send the project parameters for a cable recommendation.
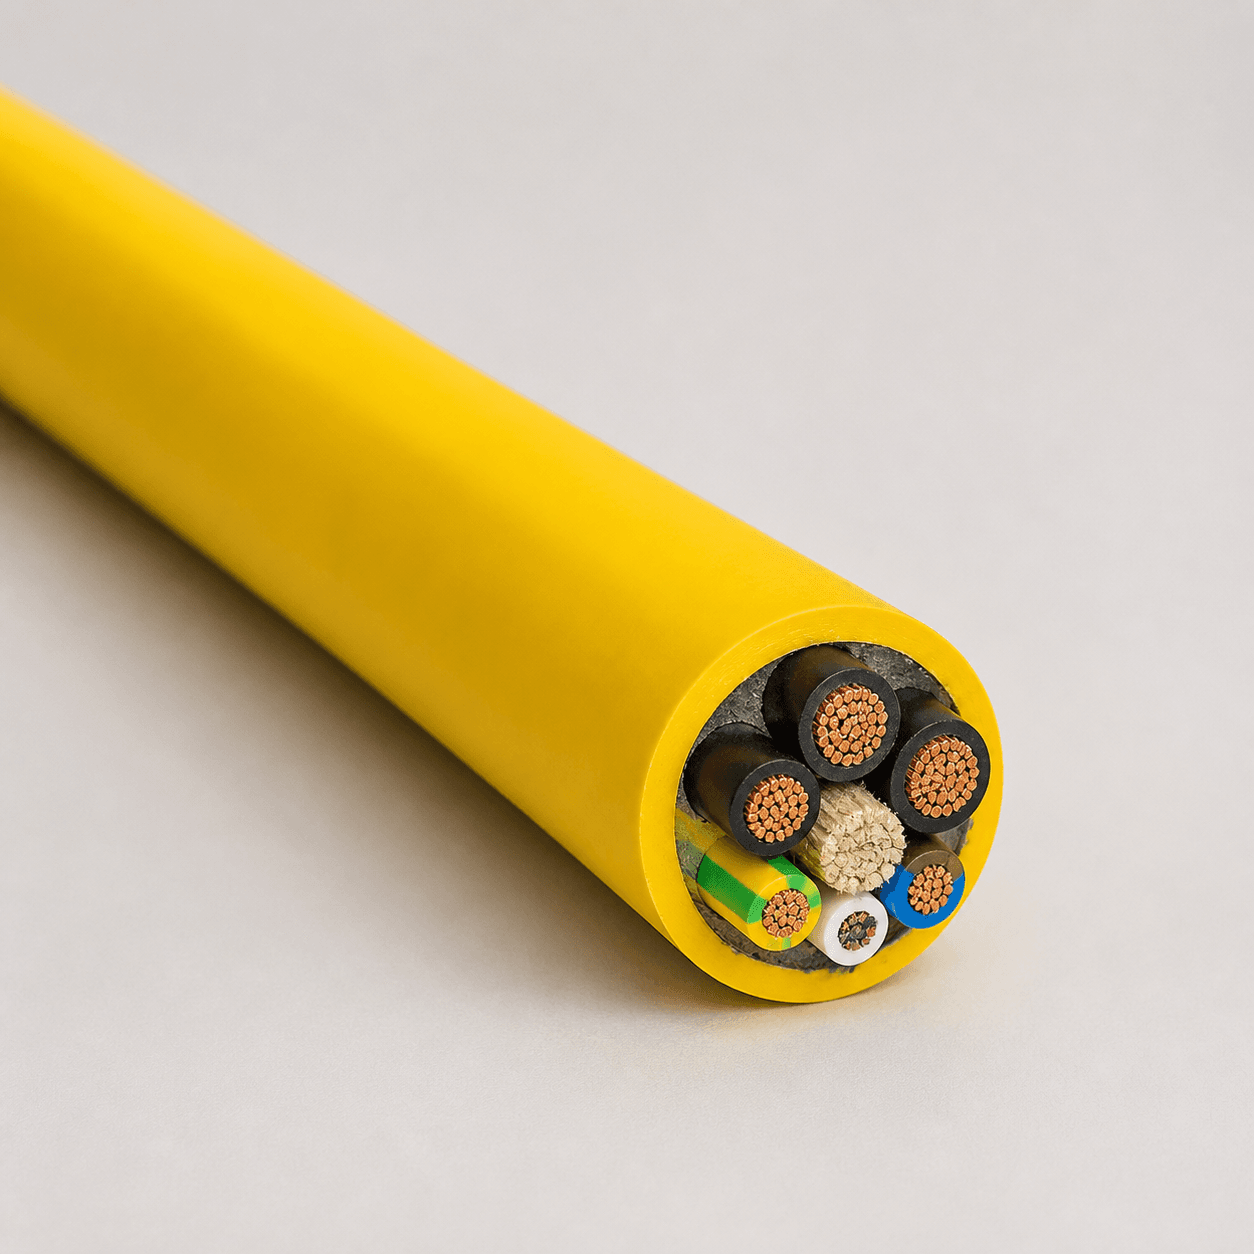
PUR flexible power and control construction for selected industrial machinery and dynamic routes.
View product →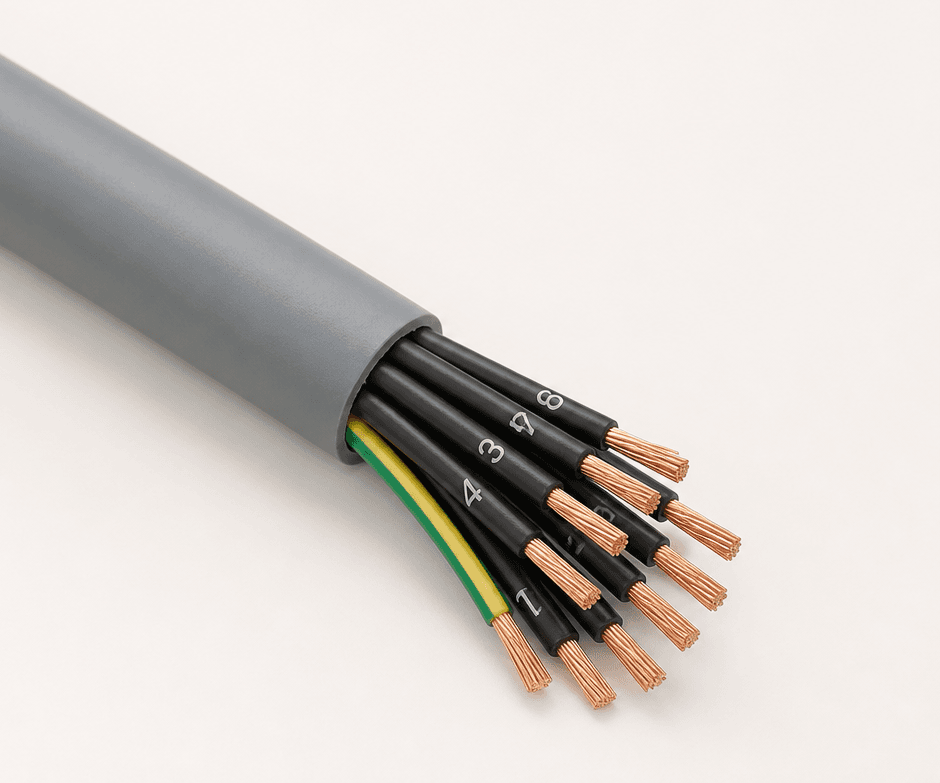
General PVC control cable for machine wiring and confirmed fixed or occasional-flex service.
View product →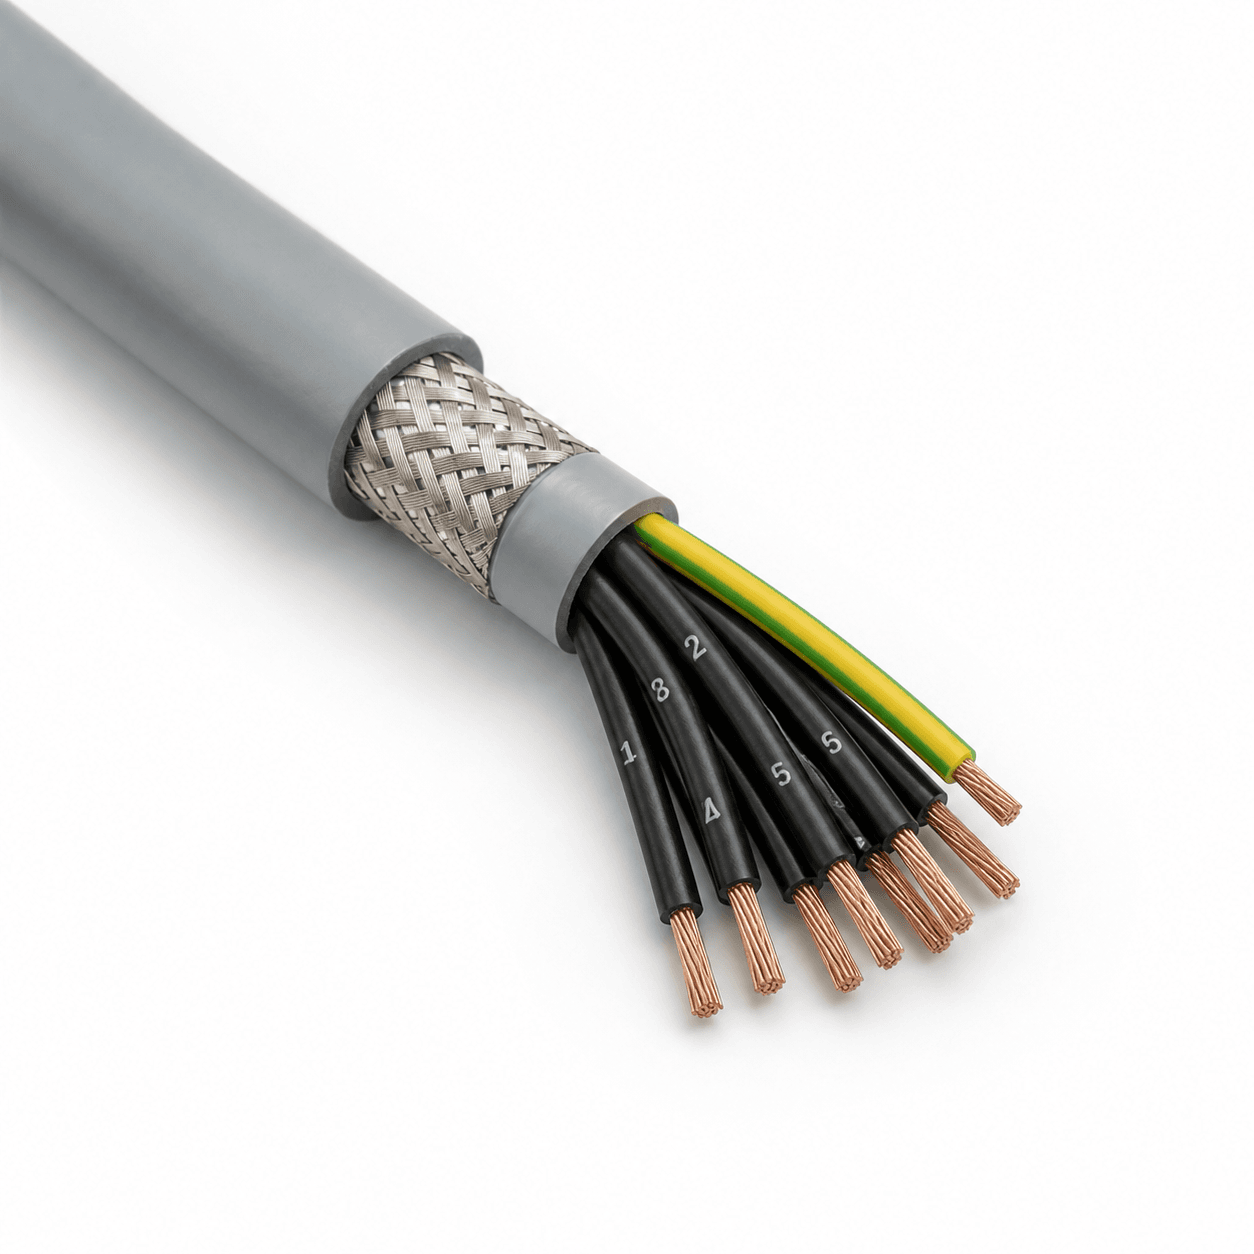
Screened PVC/PUR construction for selected flexible control and automation connections.
View product →PVC/PUR servo cable for selected automation, machine-tool and moving-equipment applications.
View product →Screened 0.6/1 kV cable for selected frequency-converter and servo motor connections.
View product →Screened PUR feedback cable for selected encoder and resolver connections in drag chains.
View product →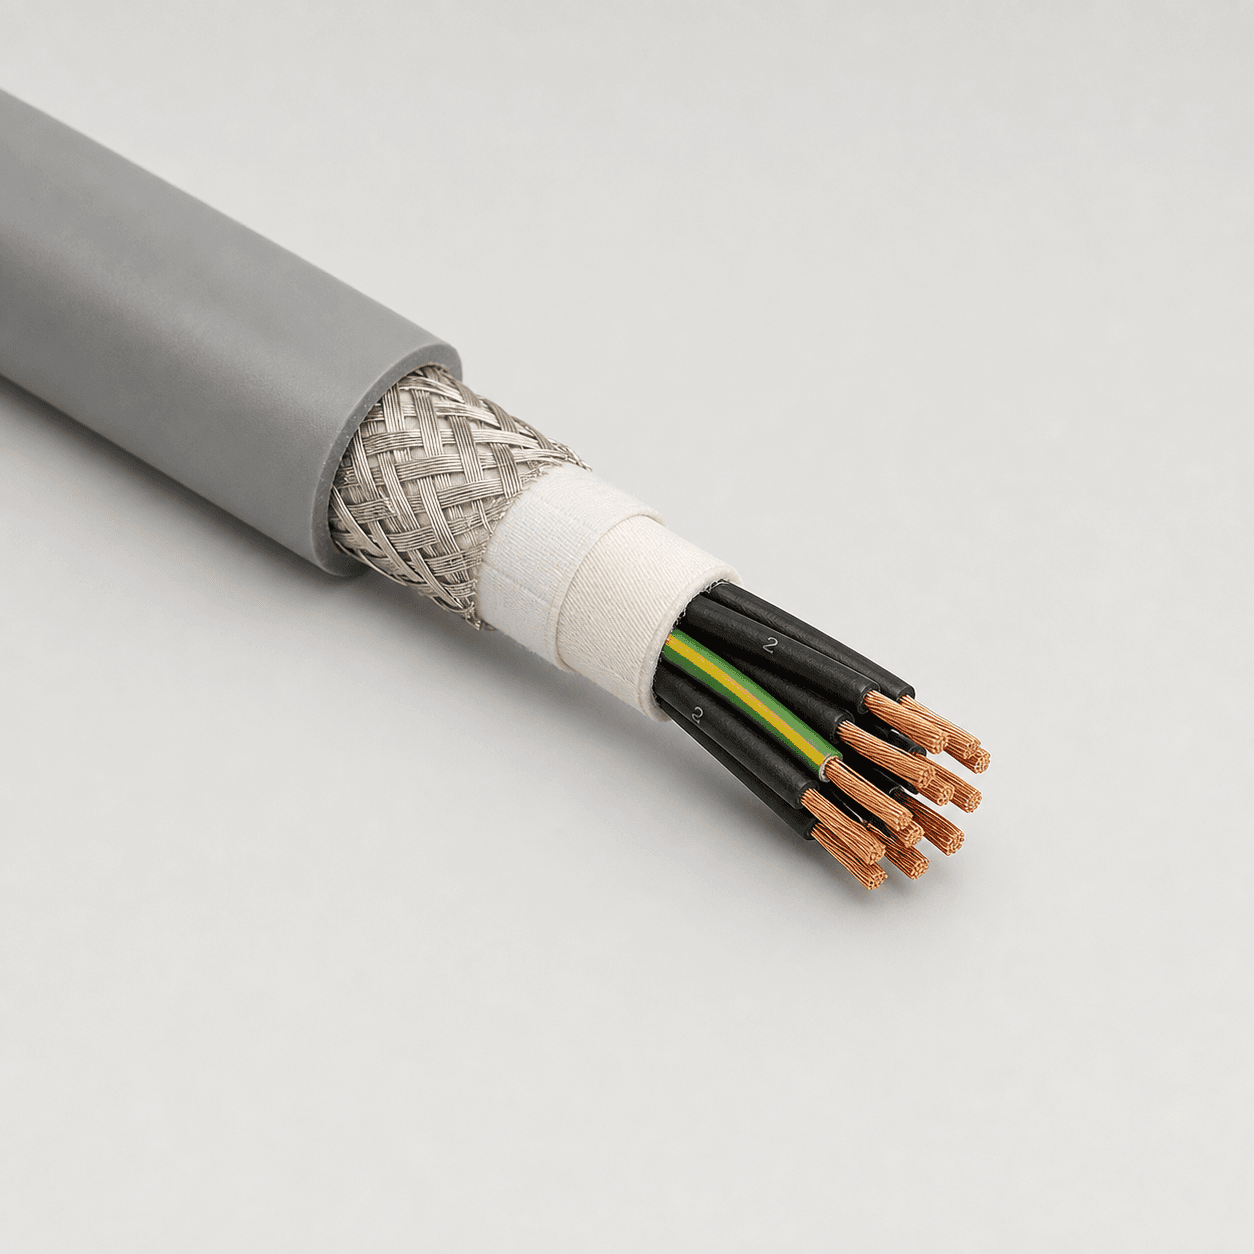
Shielded PUR drag-chain cable for selected automation and robotic equipment routes.
View product →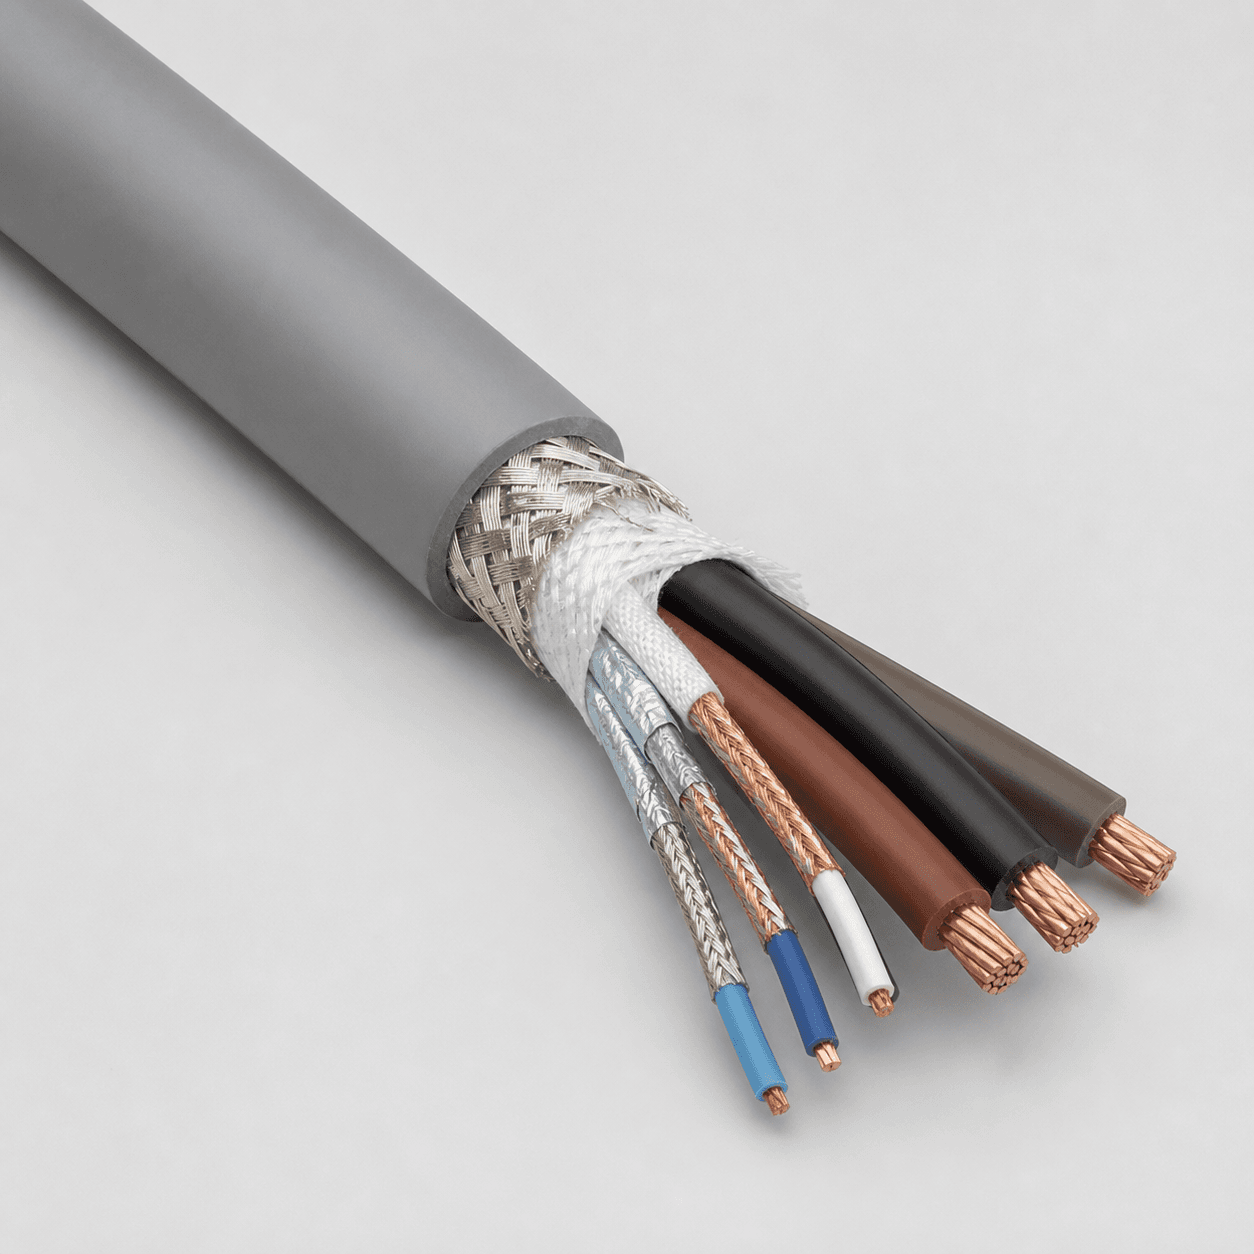
Screened composite PUR servo cable with power and signal elements for compatible motion-control systems.
View product →The required capability depends on the selected construction and application. Test evidence and operating limits should be confirmed for the exact cable rather than applied to an entire category.
Cable carriers and moving axes place cyclic bending stress on conductors, insulation and screens.
Robot and multi-axis routes require a separately evaluated response to twisting and combined motion.
Rapid machine start-stop cycles increase mechanical loading and should be included in the motion data.
Carrier contact, machine surfaces and industrial routing can influence the required sheath construction.
Machine tools and production areas may require a sheath selected for confirmed chemical exposure.
Servo drives, motors and VFD systems require coordinated cable screening, grounding and installation practice.
Start with the machine route and circuit function, then work through the mechanical, electrical and environmental constraints in a consistent order.
Identify CNC, robot, gantry, conveyor, production line or moving module.
Define power, control, servo, feedback, VFD or data.
State fixed, occasional flex, drag chain or torsion.
Provide travel distance, cable outer diameter and required bend radius.
Describe the real movement and operating cycle.
Confirm voltage, size, cores, pairs, shielding and EMC requirement.
List oil, coolant, abrasion, temperature and installation exposure.
State the required project document or destination-market approval.
Compare the complete requirement with available cable data and documentation.
When catalogue constructions do not fit the machine, TEBAOFLEX can review a project-specific cable concept using confirmed electrical and mechanical inputs. Customisation must preserve clear product documentation and a defined application boundary.
A useful quotation should connect the selected product to the requested duty and documentation. Required tests, drawings, declarations and market approvals must be identified before the order is confirmed.
Check conductor, insulation, core arrangement, screen, sheath, dimensions and marking against the agreed specification.
Confirm the applicable product data, electrical test records and requested project documents for the selected model and size.
Where flex, carrier or torsion capability is critical, request the relevant test basis and operating limits for the proposed cable.
Use these guides to compare movement duties, flexible power construction and control-cable decisions before submitting a complete request.
Compare fixed, carrier and robot-harness motion duties and the information needed for selection.
Read guide →Review application factors for flexible PUR cable in industrial machinery and moving systems.
Read guide →See construction and specification information to support a product-level technical review.
Read guide →Understand how control cable choices support reliable machine I/O and industrial automation circuits.
Read guide →These answers clarify the first selection steps. Product suitability still depends on the complete project specification.
Industrial automation equipment can use power, multicore control, servo motor, VFD, encoder feedback and communication cables. The correct construction depends on both the electrical function and whether the route is fixed, flexing, in a drag chain or subject to torsion.
A flexible cable may be intended for installation or occasional movement. A drag-chain cable is selected for controlled repeated bending in a cable carrier and should be matched to travel distance, bend radius, speed, acceleration and environmental conditions.
Only when the product data explicitly supports the required dynamic duty. A standard control cable intended for fixed or occasional-flex service should not be assumed suitable for continuous drag-chain movement.
The answer depends on the circuit. A CNC drag chain may need flexible power, servo, feedback, control and data cables. Each cable should fit the carrier geometry, movement data, EMC requirement and machine environment.
A servo motor cable carries motor power and may include brake conductors and screening. A feedback cable carries encoder or resolver signals and usually requires suitable pairs and screening to protect low-level signal integrity.
Shielding may be required when control or signal circuits are exposed to electromagnetic interference, especially near drives, motors and power cables. The screen construction and termination should follow the system EMC design.
Provide electrical function, voltage, conductor size, core count, shielding, travel distance, bend radius, speed, acceleration, movement pattern, cable-carrier arrangement, temperature and exposure to oil, coolant or abrasion.
Project-specific combinations can be reviewed when the required cores, conductor sizes, pairs, shielding, sheath material, motion profile, standards and quantity are defined. Final feasibility and documentation depend on the confirmed specification.
Send the circuit and motion data together so the technical team can compare a suitable cable family, construction and documentation path.